projects
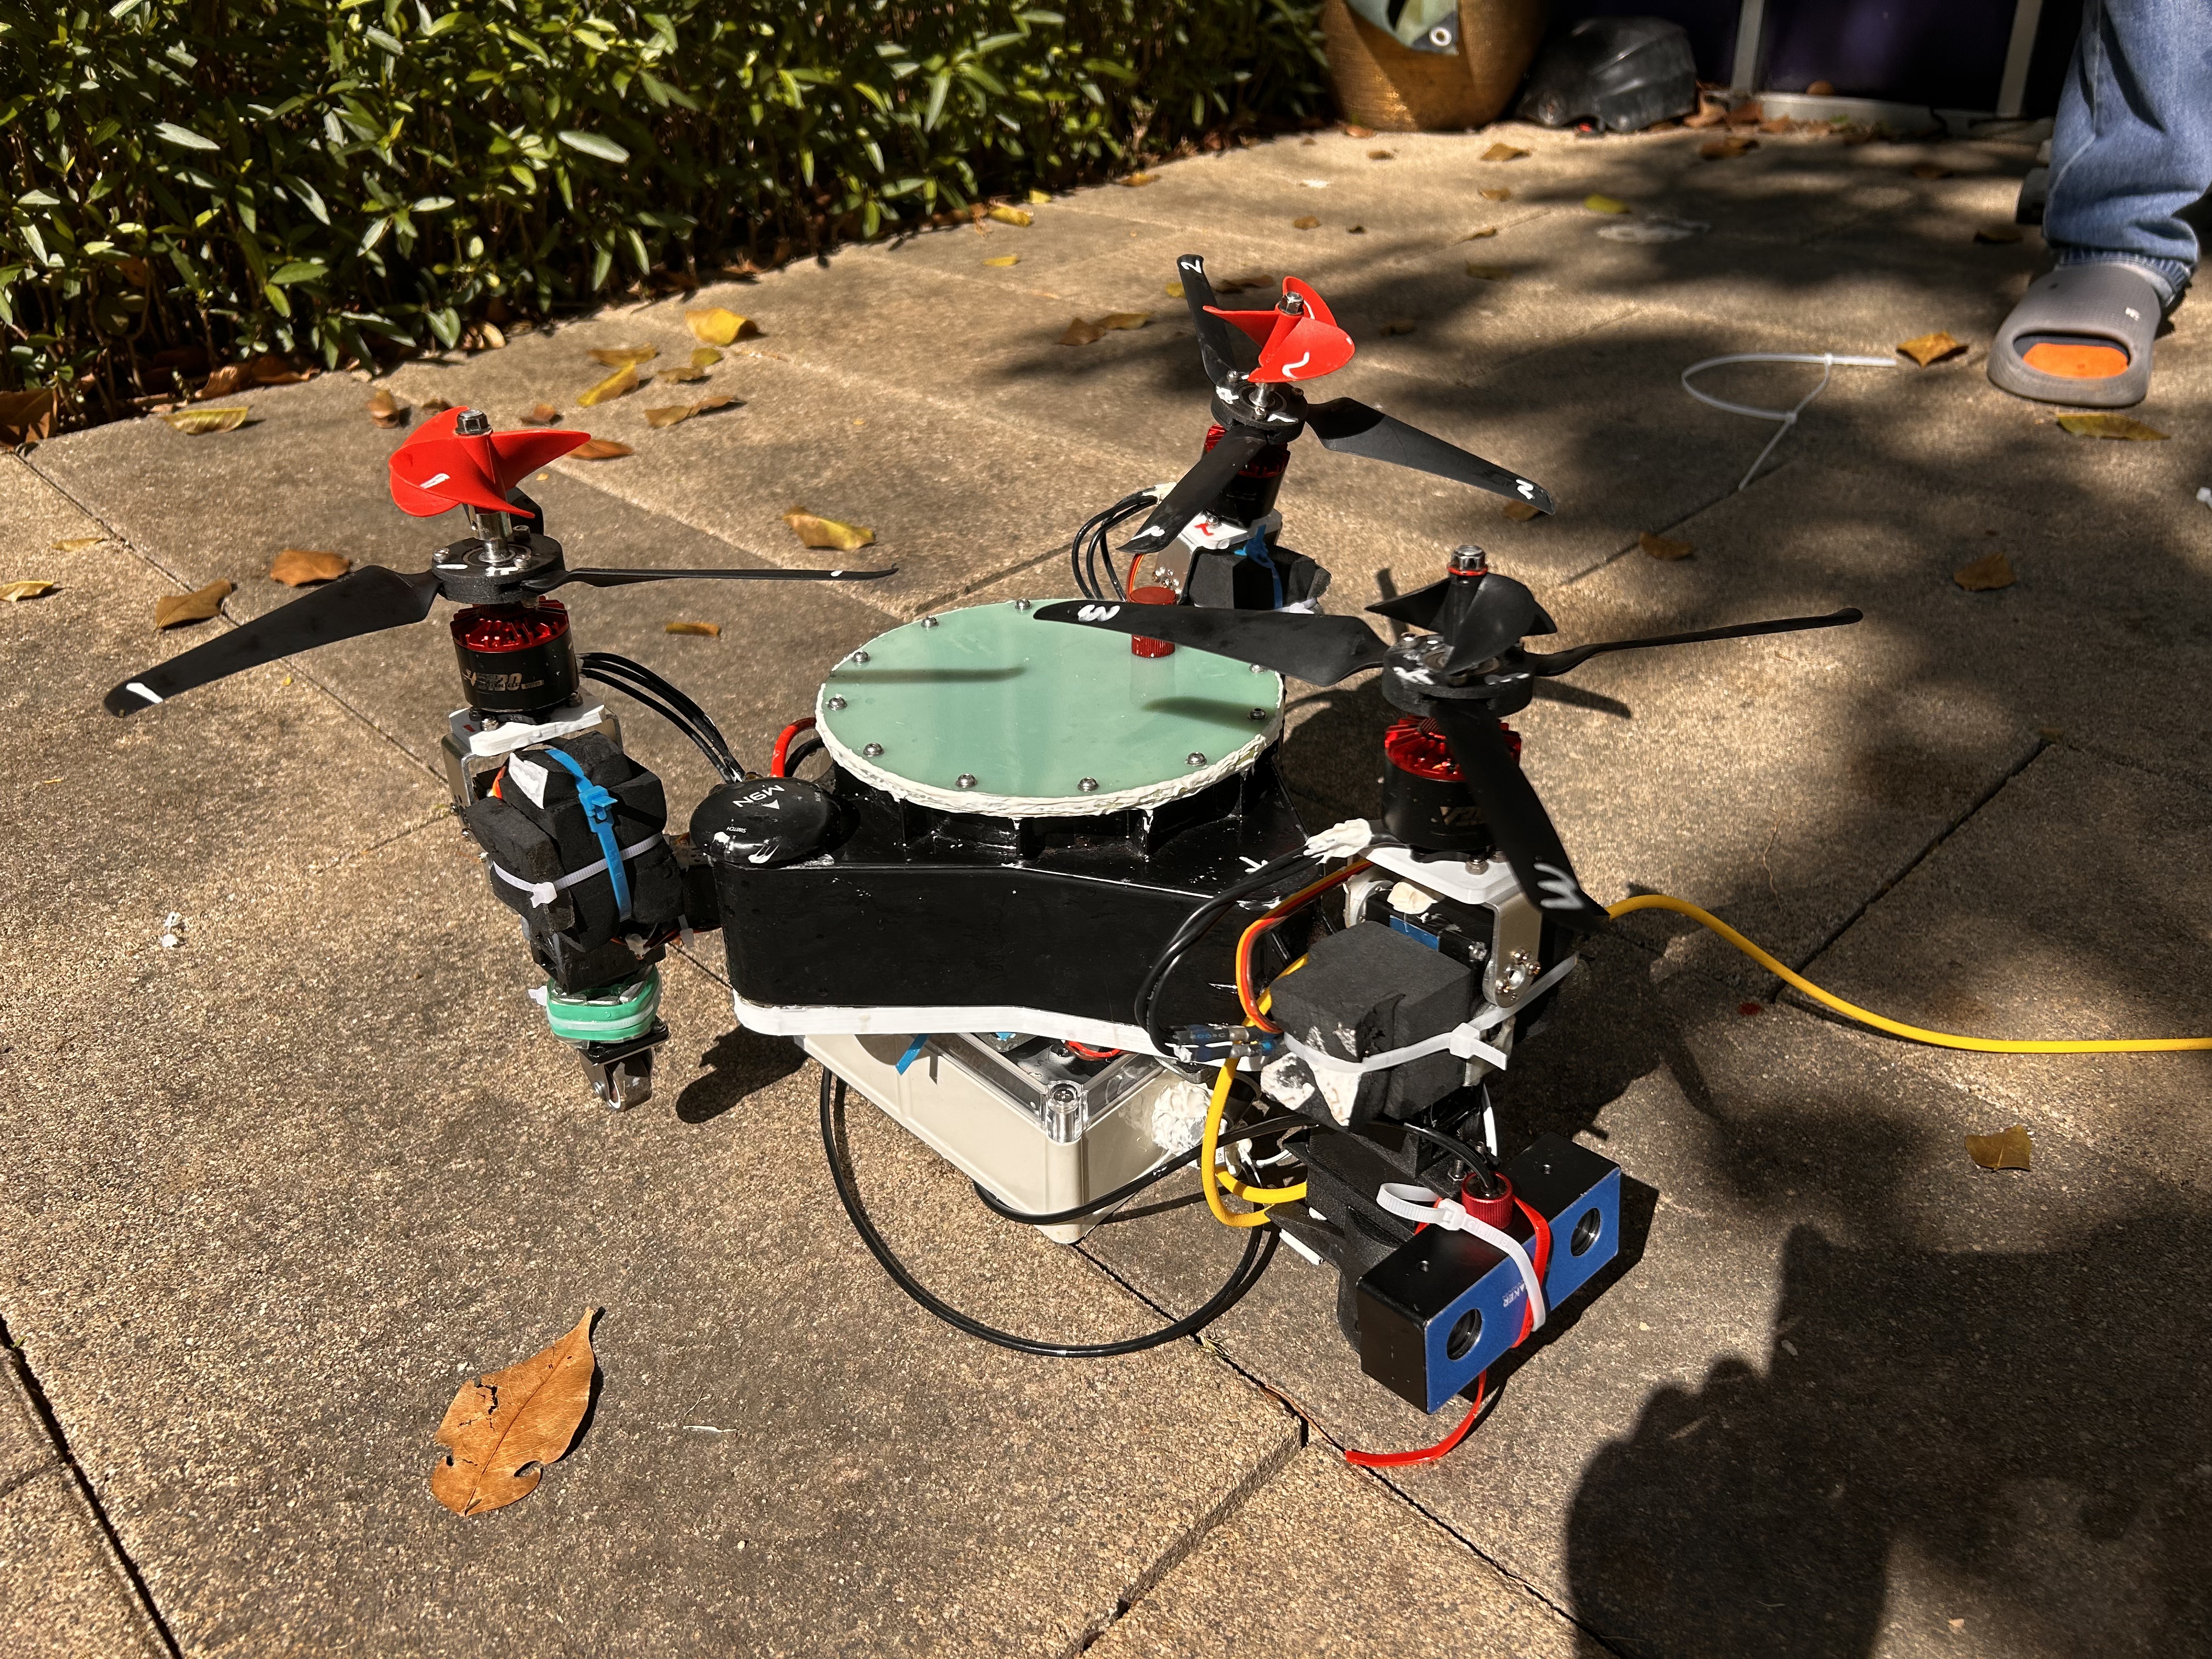
Design of Underwater Navigation and Control System for Coaxial Twin-Propeller ROV Based on ROS2 and Visual SLAM
Coaxial twin-propeller ROV navigation with stereo vision, ROS2, and ORB-SLAM3.
View project ↗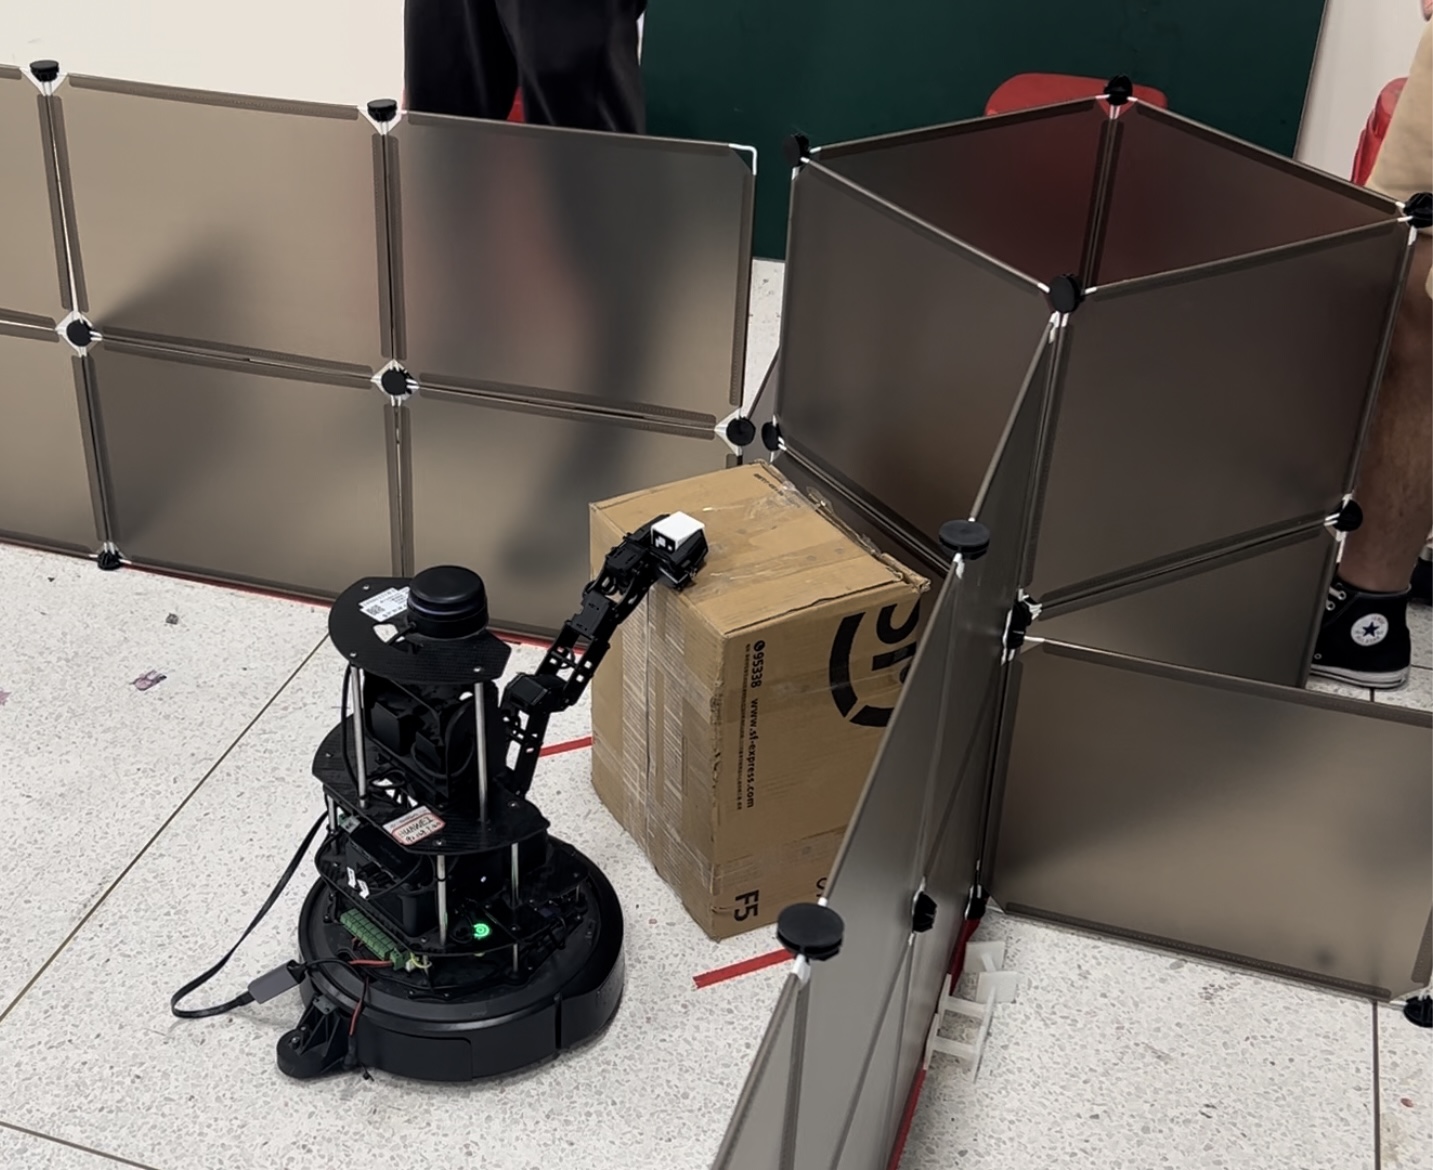
TurtleBot4 Motion Control System
Coordinated mobile locomotion and robotic-arm grasping on TurtleBot4.
View project ↗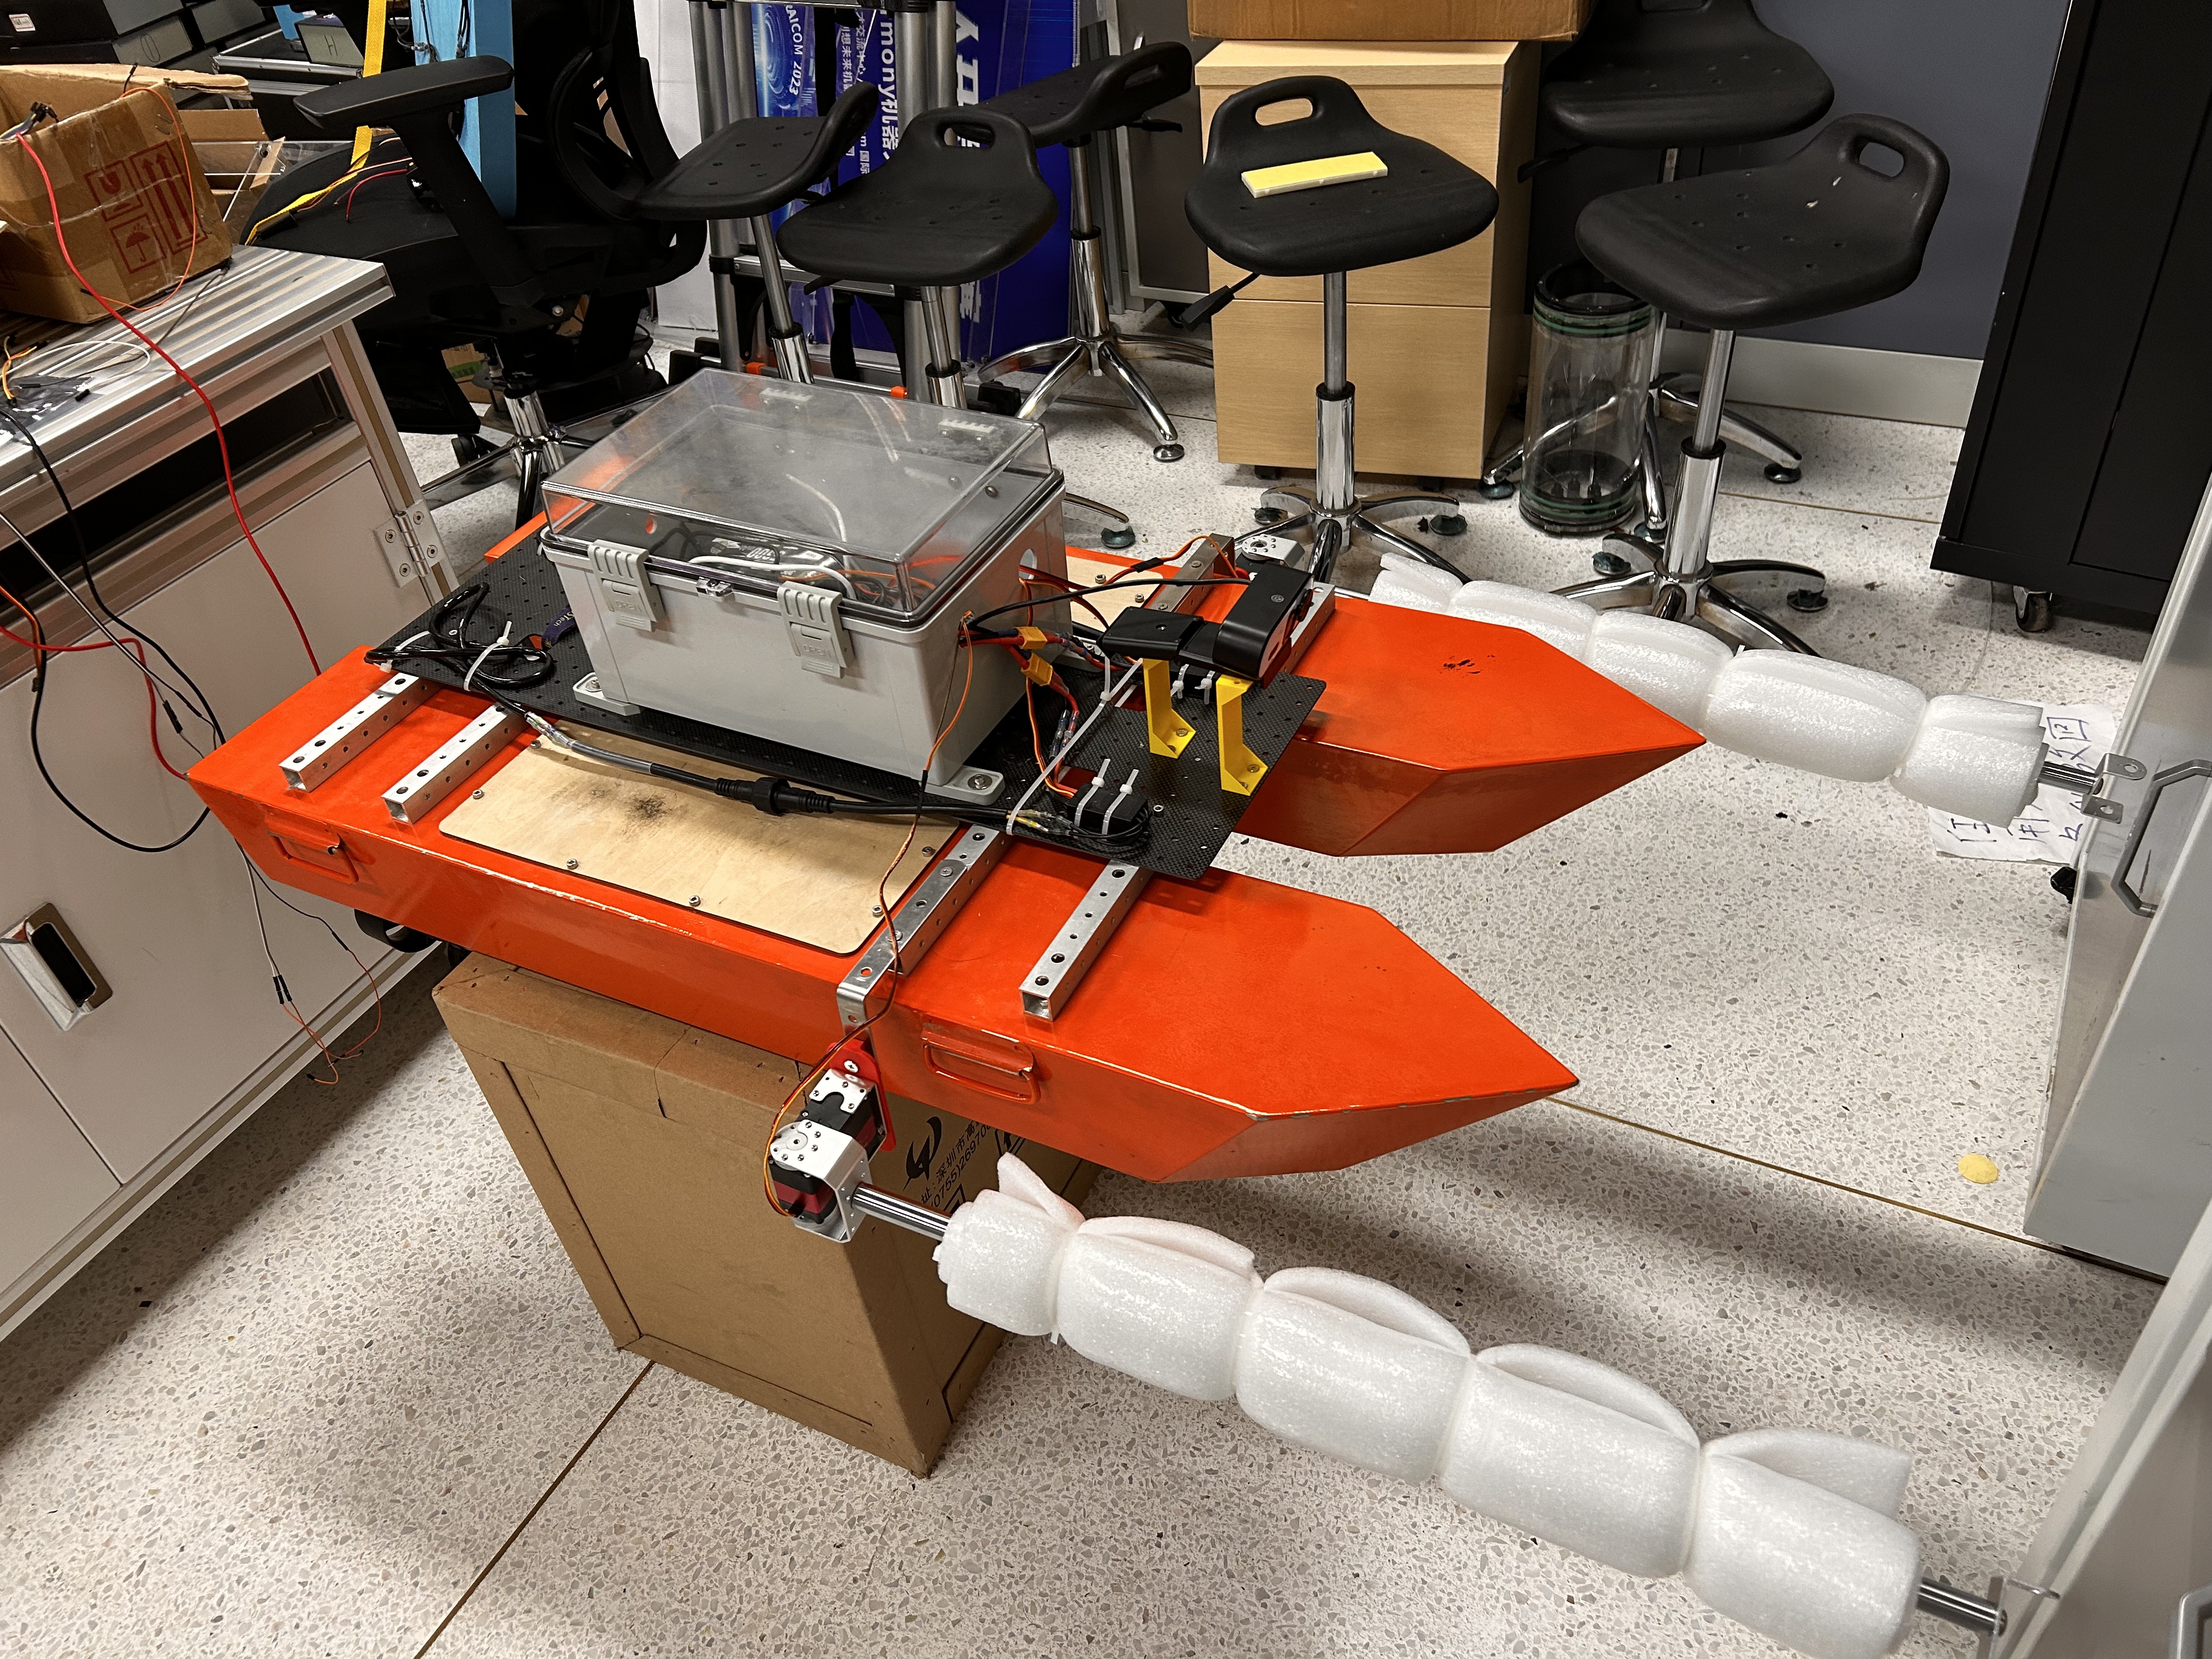
Design of Automatic Surface Water Cleaning Unmanned Boat
Vision-based target tracking and robotic waste collection on an autonomous surface vessel.
View project ↗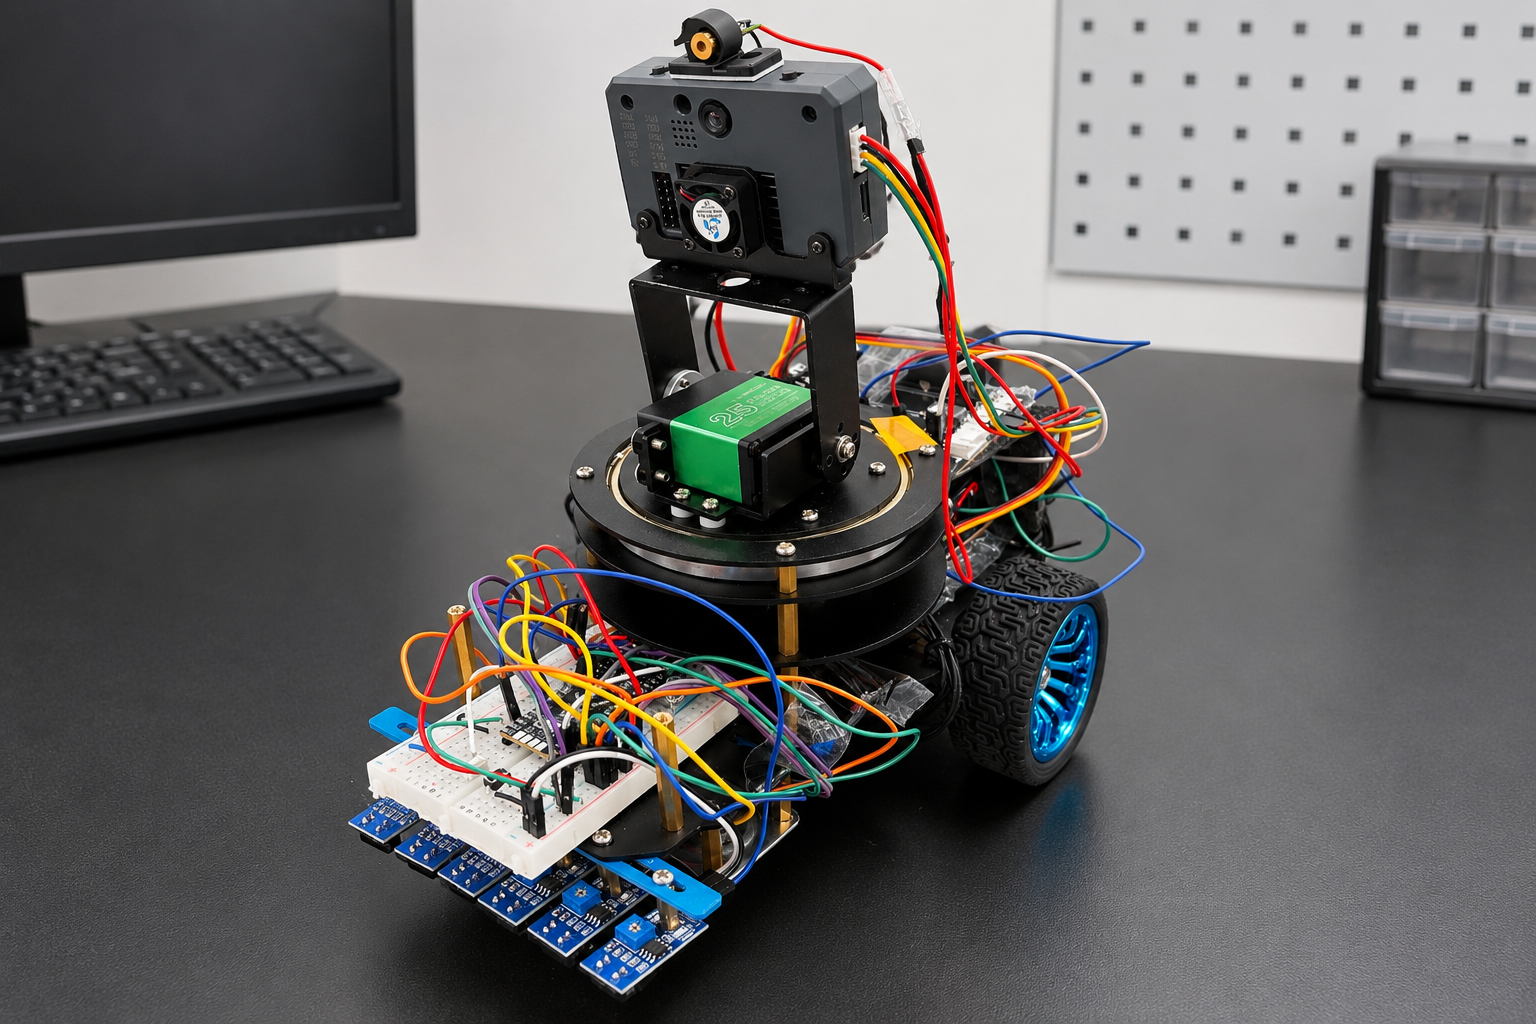
Laser Automatic Aiming Device
STM32- and K230-based vehicle for automatic laser-guided target following.
View project ↗